Following luggage
Hands-free travel — stable following even in crowded airports and stations.

The user wears a UWB tag (or just uses a phone) while the robot-side CBU5000V210 locks on with AOA angle and distance measurements, fusing IMU and odometry into smooth follow control — for luggage, service robots and campus patrol.
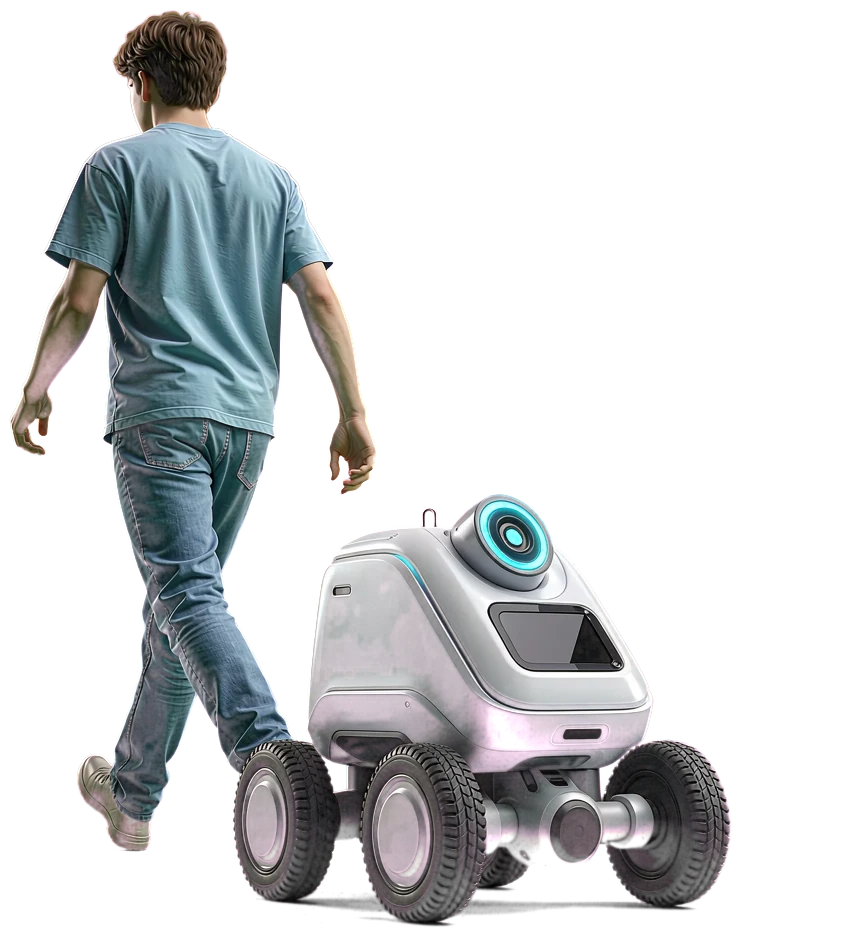
The same following solution spans consumer and industrial robots.
Hands-free travel — stable following even in crowded airports and stations.
Hotel and restaurant delivery robots that trail along without losing you.
Campus patrol robots adapt their route to the operator’s position.
Follows the operator inside the factory — flexible logistics without fixed routes.
For golf bag carts, sports gear transporters and outdoor supply carts.
Simpler, more direct spatial sensing than vision- or laser-based approaches.
Ranging + angle + multi-sensor fusion keeps the lock through occlusion and dense foot traffic.
Adjustable 0.5–3 m; speed and stop logic adapt to distance automatically.
High UWB refresh rate makes turns and acceleration feel responsive, never sluggish.
UWB penetrates obstacles; with filtering, the lock is re-acquired quickly after brief occlusion.
Stably follows the target even in complex lighting environments.
Sensing, fusion and control layers are decoupled — each layer can be customized to the robot form factor.
Module + fusion algorithms + integration support — validate your following demo fast.